Isiwara Mallawaarachchi

Hello, world.

Hi, I’m Isiwara Mallawaarachchi.

Robots that find their own way

Sensor fusion, control systems and path planning, proven in simulation before the robot ever touches the arena floor.

Learning bucket list

  • SLAM
  • FreeRTOS
  • ArduPilot
  • PX4

Tools I use

  • Sensor fusion
  • Control systems
  • Path planning
  • Computer vision
  • Gazebo
  • Webots
  • STM32
  • C / C++

Built to ship

End-to-end web applications: RESTful APIs in FastAPI and Spring Boot, React and TypeScript front ends, and relational data models in MySQL, built to ship.

Tools I use

  • FastAPI
  • React
  • Spring Boot
  • TypeScript
  • MySQL
  • Docker
  • Git
  • Linux

Oct 2026 — Now

RoboticGen

Software Engineering Intern · Hybrid

Building web apps with FastAPI and React, and learning how real products get shipped.

  • Python
  • FastAPI
  • React

What I work with

STM32
C
Python
React
C++
Arduino
Espressif
Xilinx Vivado
GzGazebo
WbWebots
Fusion 360
Raspberry Pi
FastAPI
Next.js
TypeScript
JavaScript
Tailwind
Astro
SQLite
Linux
Git
Docker

4-bit CPU in VHDL · BASYS 3 FPGA

A 4-bit processor written in VHDL and run on a BASYS 3 FPGA, each block verified with its own Vivado testbench.

A calendar that negotiates

A calendar that checks whether an event can actually happen, settles clashes by priority and reshuffles your day when plans change.

B-Trust MIMS

A three-tier banking system where stored procedures guard every transaction and a nightly job pays the interest.

Next build
in progress.

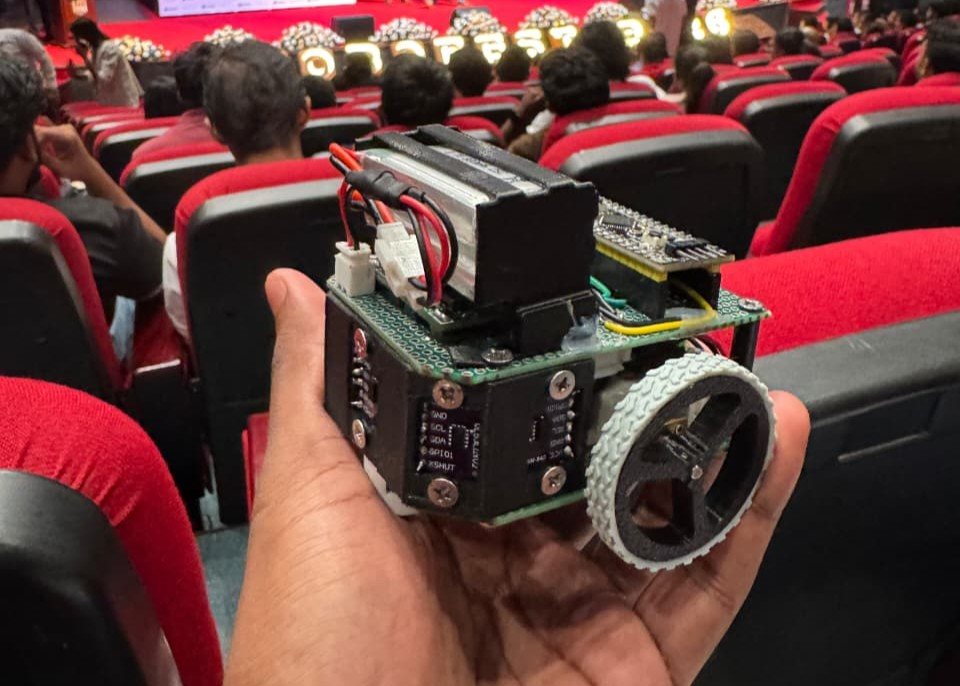
Botato micromouse held in a hand at ROBOFEST 2026
2ndPlace

Sep 2026

Full-size micromouse · University category · SLIIT

A palm-sized robot that maps a 16×16 maze by itself and races to the centre. I built its electronics by hand and led the firmware: reading the sensors, working out where it is, keeping it steady and solving the maze. 2nd place on our first attempt.

Team

Team Botato

Code
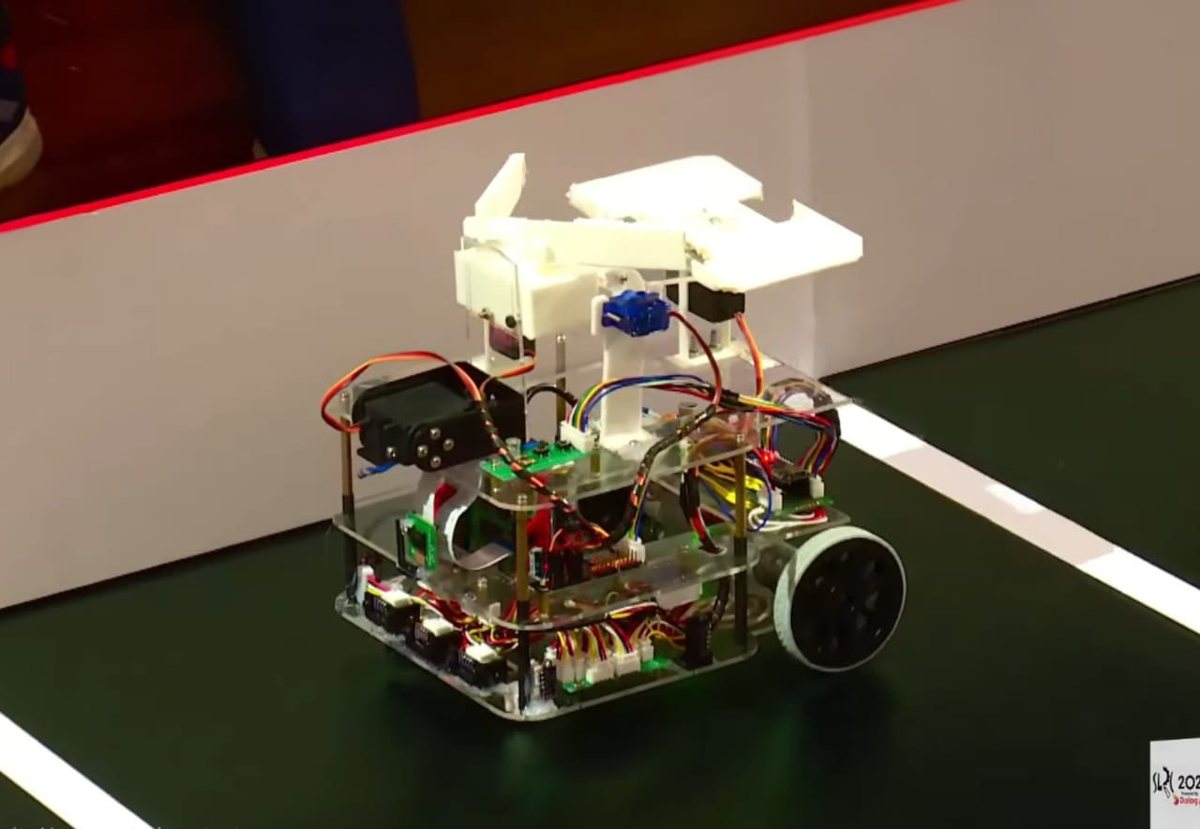
Team Botato's SLRC 2026 robot on the competition arena
2ndPlace

Mar — Apr 2026

Sri Lanka Robotics Challenge · Electronic Club, UoM

I wrote the sensor-reading and low-level control code the team's task logic ran on, and helped my teammates with the Gazebo simulation.

Team

Team Botato

Code
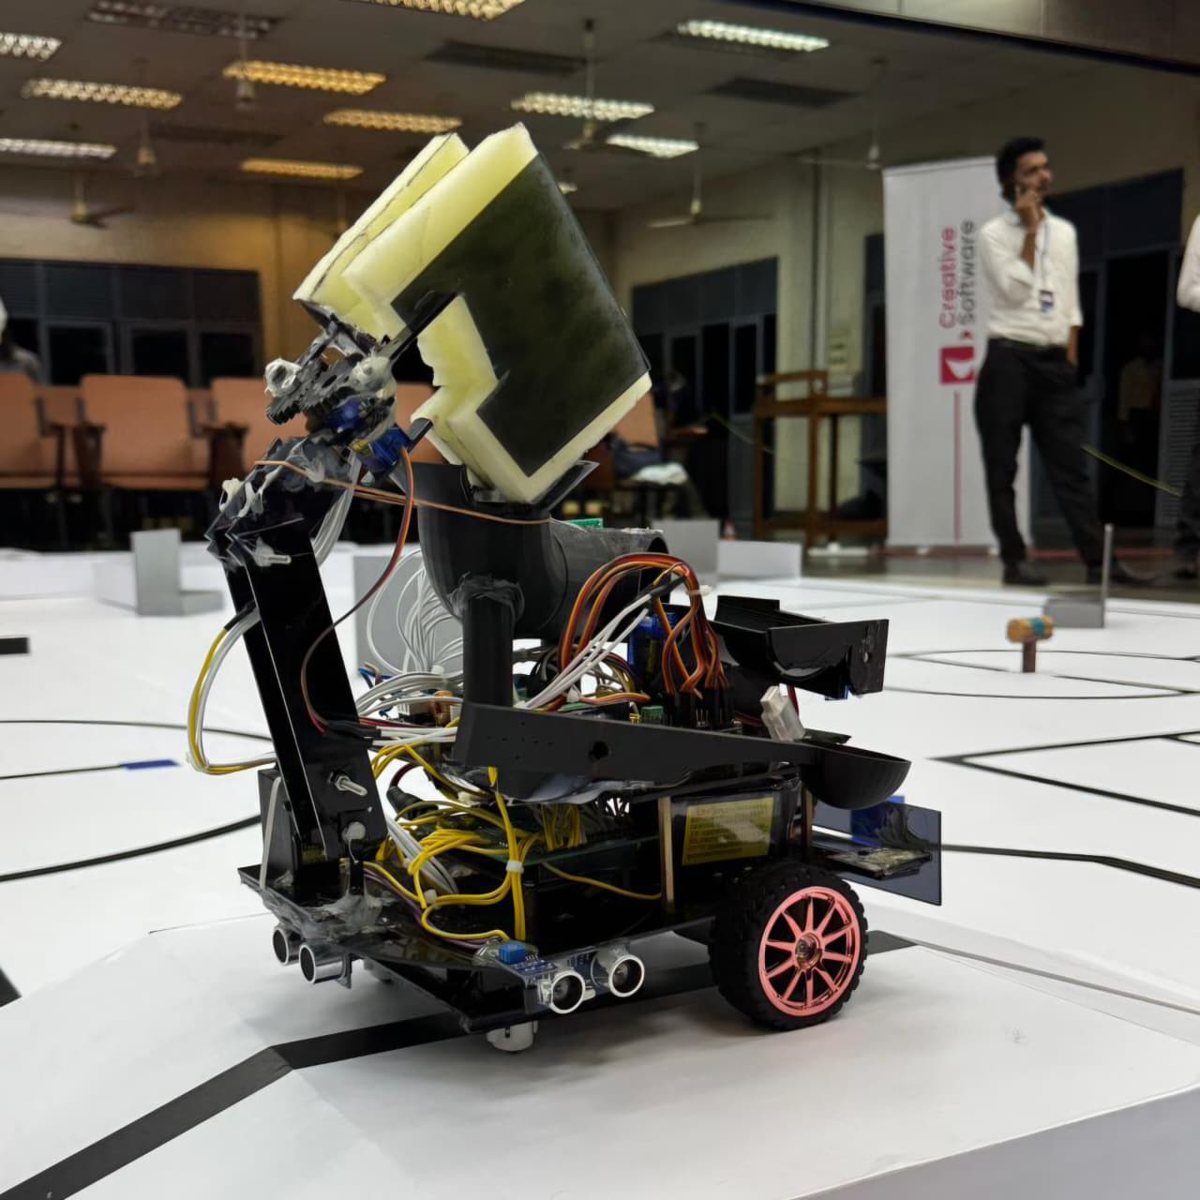
Team Botato's Xbotix 2025 robot with a gripper arm on the arena
5thPlace

Oct — Nov 2025

University of Ruhuna

Wired the robot's electronics, helped design the hardware, and wrote reusable Arduino routines for line following and wall navigation.

Team

Team Botato

Code
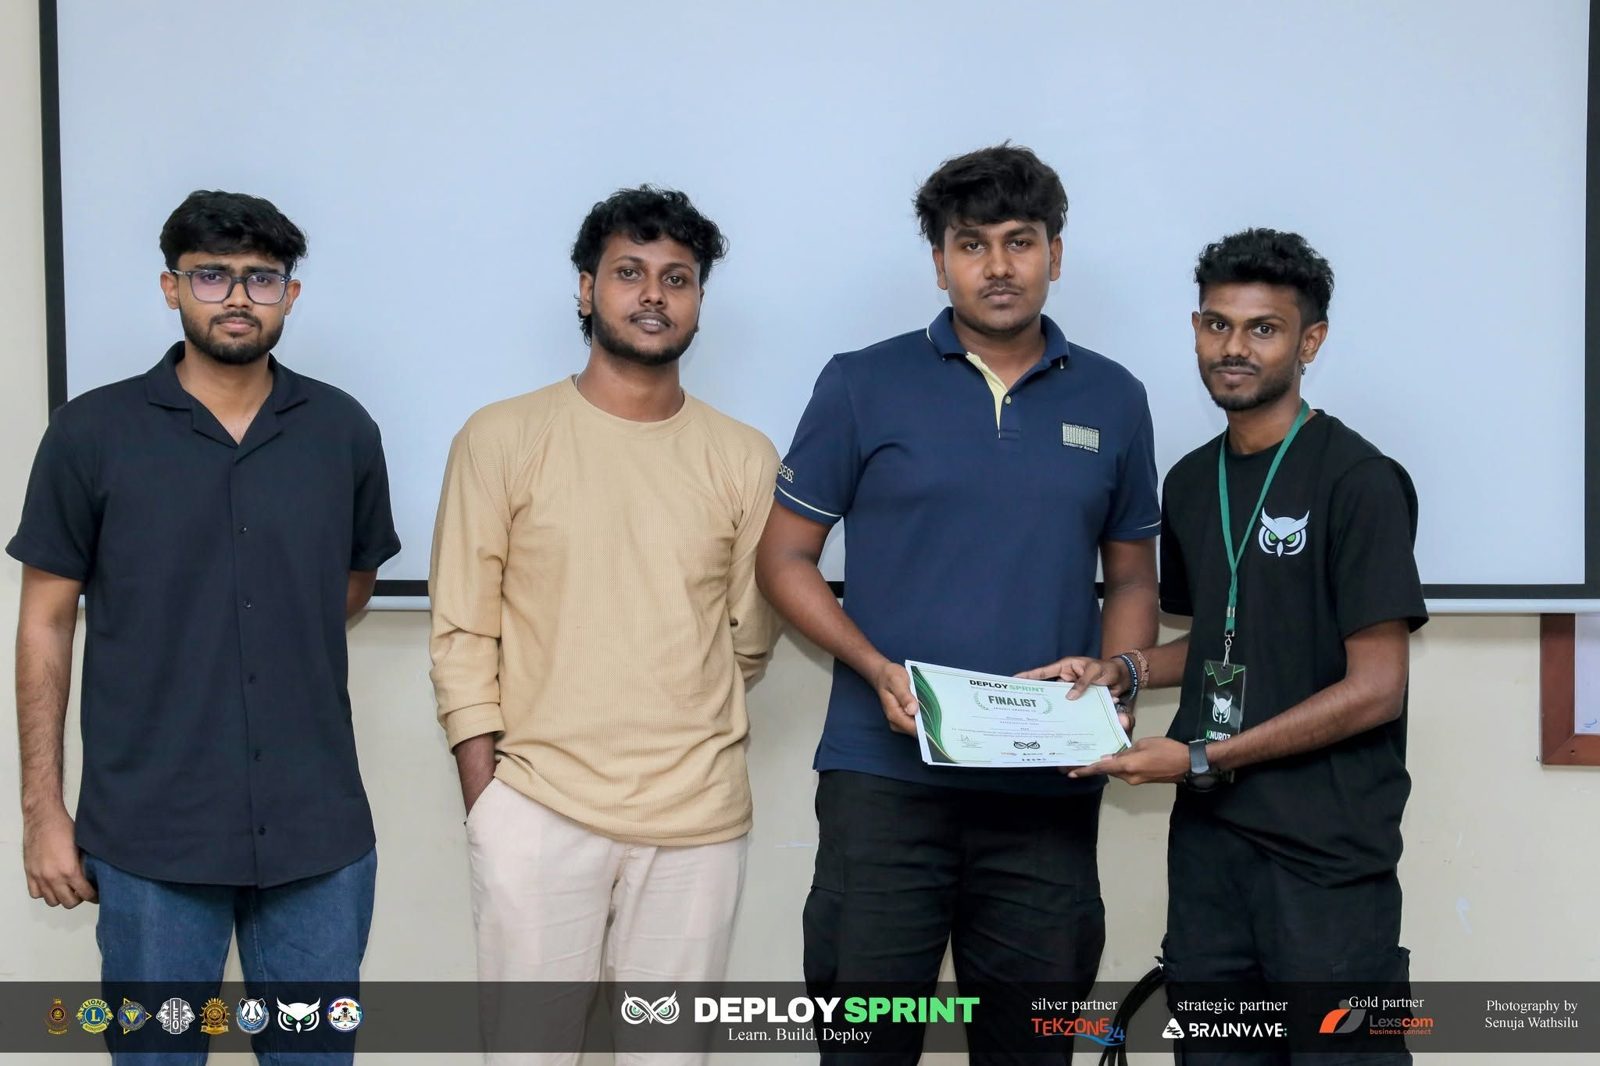
Team PIKK receiving the Deploy Sprint 2026 finalist certificate
4thPlace

2026

DevOps & SRE competition by Knurdz

45 teams, top 15 in the finale, 4th overall, running live CI/CD, releases and rollbacks against the clock.

Team

Team PIKK

isiwaramallawaarachchi@gmail.com

Let’s build something that moves.

Email me